Calculate screw lead angle from lead and pitch diameter, convert pitch or TPI to lead, and consult a simplified Kennametal LT shim planning lookup. Holder hand affects the part prefix; shared angle boundaries and the full catalog must be checked before machining.
- All Construction Calculators
- Reference Angle Calculator
- Arctan Calculator
- Coterminal Angle Calculator
- Helix Angle Calculator
- Lead Screw Efficiency Calculator
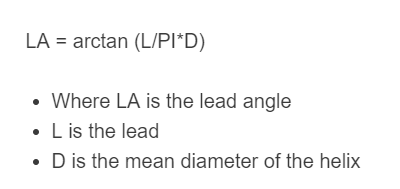
Lead Angle Formula
The following formula is used to calculate the lead angle of a helix or screw.
- Where LA is the lead angle
- L is the lead
- D is the mean diameter of the helix
To calculate a lead angle, divide the lead by (pi × mean diameter). Finally, take the arc tangent (arctan) of this result.
Lead Angle Definition
A lead angle is the angle between a thread (helix) and a plane perpendicular to the screw axis (a plane normal to the axis), usually evaluated at the pitch/mean diameter. This can also be applied to helices.
How to calculate lead angle?
How to calculate a lead angle
- First, measure the lead of the helix
The lead of the helix is the axial distance traveled during one complete turn along a helix or screw thread. Measure this in whichever is your preferred unit; just make sure the units are consistent.
- Next, measure the mean diameter
This is the diameter at which you want the lead angle. For screw threads, this is typically the pitch (mean) diameter, which is usually taken from a thread specification or measured directly (it is not the radius).
- Finally, calculate the lead angle
Enter the information from steps 1 and 2 into the equation above to calculate the lead angle.
FAQ
A lead angle is the angle between the helix (thread) and a plane perpendicular to the screw axis, usually measured at the pitch (mean) diameter.
A thread is a helical ridge (or groove) on a cylindrical surface that, when mated with another thread (like a nut), can provide fastening and convert rotation into linear motion.